
Low Earth orbit is the most valuable industrial territory humanity has ever occupied, and we are littering it at a pace no cleanup effort has yet matched. Space surveillance networks now track roughly 40,000 objects circling Earth — and only about 11,000 of them are working satellites. The rest is debris: spent rocket stages, dead spacecraft, shrapnel from explosions and collisions. Modeling by the European Space Agency puts the true population far higher — more than 1.2 million fragments between one and ten centimeters, and on the order of 140 million pieces larger than a millimeter. At orbital velocities of seven to eight kilometers per second, with closing speeds between objects that can exceed ten kilometers per second, a one-centimeter bolt carries the energy of a hand grenade. A fleck of paint can crater a window. Nothing in orbit is armored against the environment we have created.
This is the problem Space Dust Industries takes its name from. Debris removal is not a single technology; it is a systems problem spanning surveillance, prediction, rendezvous, capture, and disposal — and at every stage, the binding constraint is increasingly not propulsion or materials but autonomy. That is where we are placing our bet.
A congested orbit, and a clock that only runs one way
The numbers have been moving in the wrong direction. In 2024 alone the tracked population grew by thousands of objects, driven partly by record launch rates and partly by major fragmentation events — a single rocket-body breakup can scatter hundreds of trackable fragments and untold smaller ones across a heavily used altitude band. Meanwhile the operational population is exploding: large broadband constellations have pushed the number of active satellites past anything envisioned when debris-mitigation guidelines were first written.
The long-term risk was articulated back in 1978, when NASA scientist Donald Kessler showed that above a critical density, collisions between orbiting objects generate debris faster than atmospheric drag removes it — each impact seeding the next in a slow-motion chain reaction. The Kessler syndrome is not a Hollywood cascade that unfolds in an afternoon; it is a compounding process measured in decades. ESA’s own assessment is blunt: even if all launches stopped today, the debris population in some LEO bands would continue to grow from collisions among objects already there. Mitigation alone is no longer sufficient. Some of what is up there has to come down.
Regulators have started to move. In the United States, the FCC’s “five-year rule” — in force since September 2024 — requires satellites ending their missions below 2,000 kilometers to deorbit within five years, replacing the old 25-year guideline. It is a meaningful tightening, but it governs future spacecraft. The thousands of derelict objects already in orbit, including hundreds of multi-ton rocket bodies, are grandfathered into the sky. Removing them is the job of a discipline still in its infancy: active debris removal, or ADR.
What the first removal missions are teaching us
ADR has moved from paper studies to flight hardware in less than a decade. The UK-led RemoveDEBRIS experiment demonstrated net and harpoon capture against test targets in 2018 — proof that the physics works. Astroscale’s ELSA-d mission then demonstrated magnetic capture and release of a prepared client satellite, and its follow-on ELSA-M is being built as the first commercial end-of-life removal service for satellites fitted with a docking plate.
The harder problem is unprepared debris — objects that were never designed to be caught. Here the landmark is Astroscale’s ADRAS-J, flown under Phase I of JAXA’s Commercial Removal of Debris Demonstration (CRD2) program. In 2024 it became the first spacecraft to rendezvous with and closely inspect a large piece of genuine debris, flying around a derelict Japanese upper stage and imaging it from tens of meters away before completing its mission and lowering its own orbit. The follow-on ADRAS-J2 mission aims to return to the same rocket body, grapple it with a robotic arm, and deorbit it. In Europe, ESA’s ClearSpace-1 — replanned in 2024 after its original target was itself struck by debris, a grim proof of the underlying problem — now aims to capture and deorbit the retired Proba-1 satellite later this decade.
Every one of these missions reinforces the same lesson: the capture is the easy-looking part that is actually hard. A dead satellite does not hold still. It may be tumbling unpredictably, its surfaces degraded by decades of ultraviolet exposure and thermal cycling, its geometry known only from old drawings and blurry radar returns. Approaching it safely requires a spacecraft that can perceive, decide, and act on its own — because at these ranges and closing rates, a human in a ground loop is too slow.
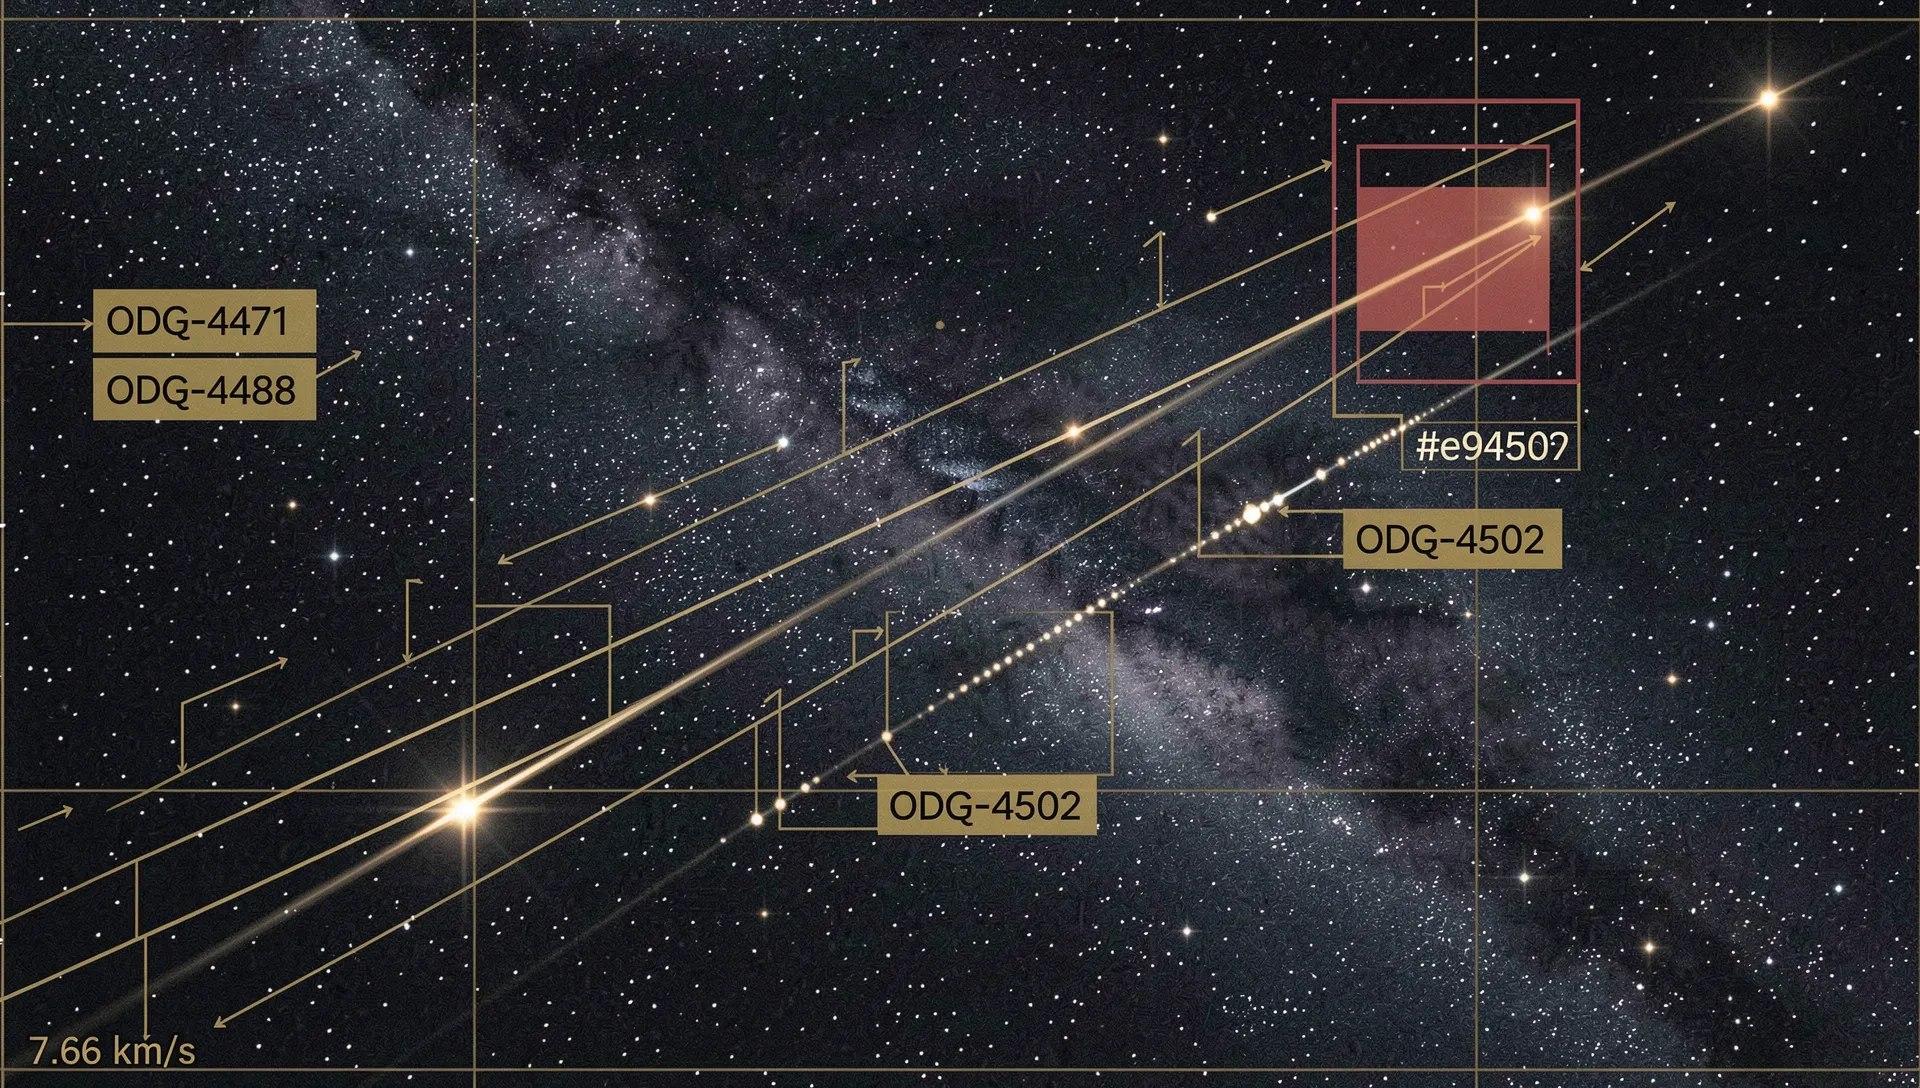 Perception is the foundation: before any object can be captured, its position, spin state, and structure must be estimated in real time from onboard sensors.
Seeing the sky: surveillance, conjunction assessment, and machine perception
Debris removal begins on the ground, with space situational awareness. Radar and optical networks maintain the catalog that every operator depends on for conjunction assessment — the daily work of screening close approaches and deciding when to burn propellant to dodge. The volume is already straining human processes: major constellation operators now perform tens of thousands of avoidance maneuvers per year, and even the International Space Station has had to move dozens of times over its life to sidestep tracked fragments. As the catalog grows toward the tens of thousands of objects and sensors improve to see smaller ones, conjunction screening becomes exactly the kind of high-volume, pattern-rich prediction problem that machine learning is built for.
Onboard the servicer, the same shift applies. Our research focuses on computer vision for non-cooperative targets: detecting a debris object against star fields and Earth clutter, classifying it, and estimating its six-degree-of-freedom pose and spin from monocular and multi-spectral imagery — the perception stack that any autonomous rendezvous ultimately rests on. These are the same model families we train today on our on-premises multi-GPU cluster for terrestrial 3D-scanning and robotics work: photogrammetry, neural pose estimation, and reinforcement-learned control policies that must run on power-limited edge hardware without a data center behind them. A spacecraft is the ultimate edge device — bandwidth-starved, radiation-constrained, and unforgiving — and building AI that performs offline, on modest compute, is precisely the discipline SDI practices every day.
Getting a grip: capture without a handle
Once a target’s motion is understood, something has to physically take hold of it. The field has converged on a small set of approaches, each with real trade-offs. Nets tolerate uncertainty in target shape and spin but make the captured object hard to control afterward. Harpoons work on structural panels but risk creating fragments. Robotic arms — the approach chosen for ADRAS-J2 and ClearSpace-1 — offer rigid, controllable capture, but demand exquisite relative navigation and a graspable feature. Researchers are also pursuing adhesion that needs no feature at all: gecko-inspired dry adhesives, whose microscopic fibrillar structures grip smooth surfaces in vacuum and have been tested aboard the ISS, and electrostatic attraction that can hold non-magnetic composite skins.
That adhesive frontier is where one of SDI’s founding concepts lives. Our “fly paper” webbing concept is a deployable, compliant capture surface — imagine a spider’s web crossed with a drag net — engineered to spread contact loads across a tumbling object and absorb its momentum gradually rather than in one violent jolt. The materials problem is severe: an adhesive membrane must survive swings from roughly −150 °C to well over +100 °C, atomic-oxygen erosion, and years of UV. We treat this as a concept under active research, not a product — our contribution today is on the intelligence side: simulation environments in which capture strategies against tumbling bodies can be trained and stress-tested by reinforcement learning long before any hardware flies, so that the contact dynamics, timing, and failure modes are understood in silicon first.
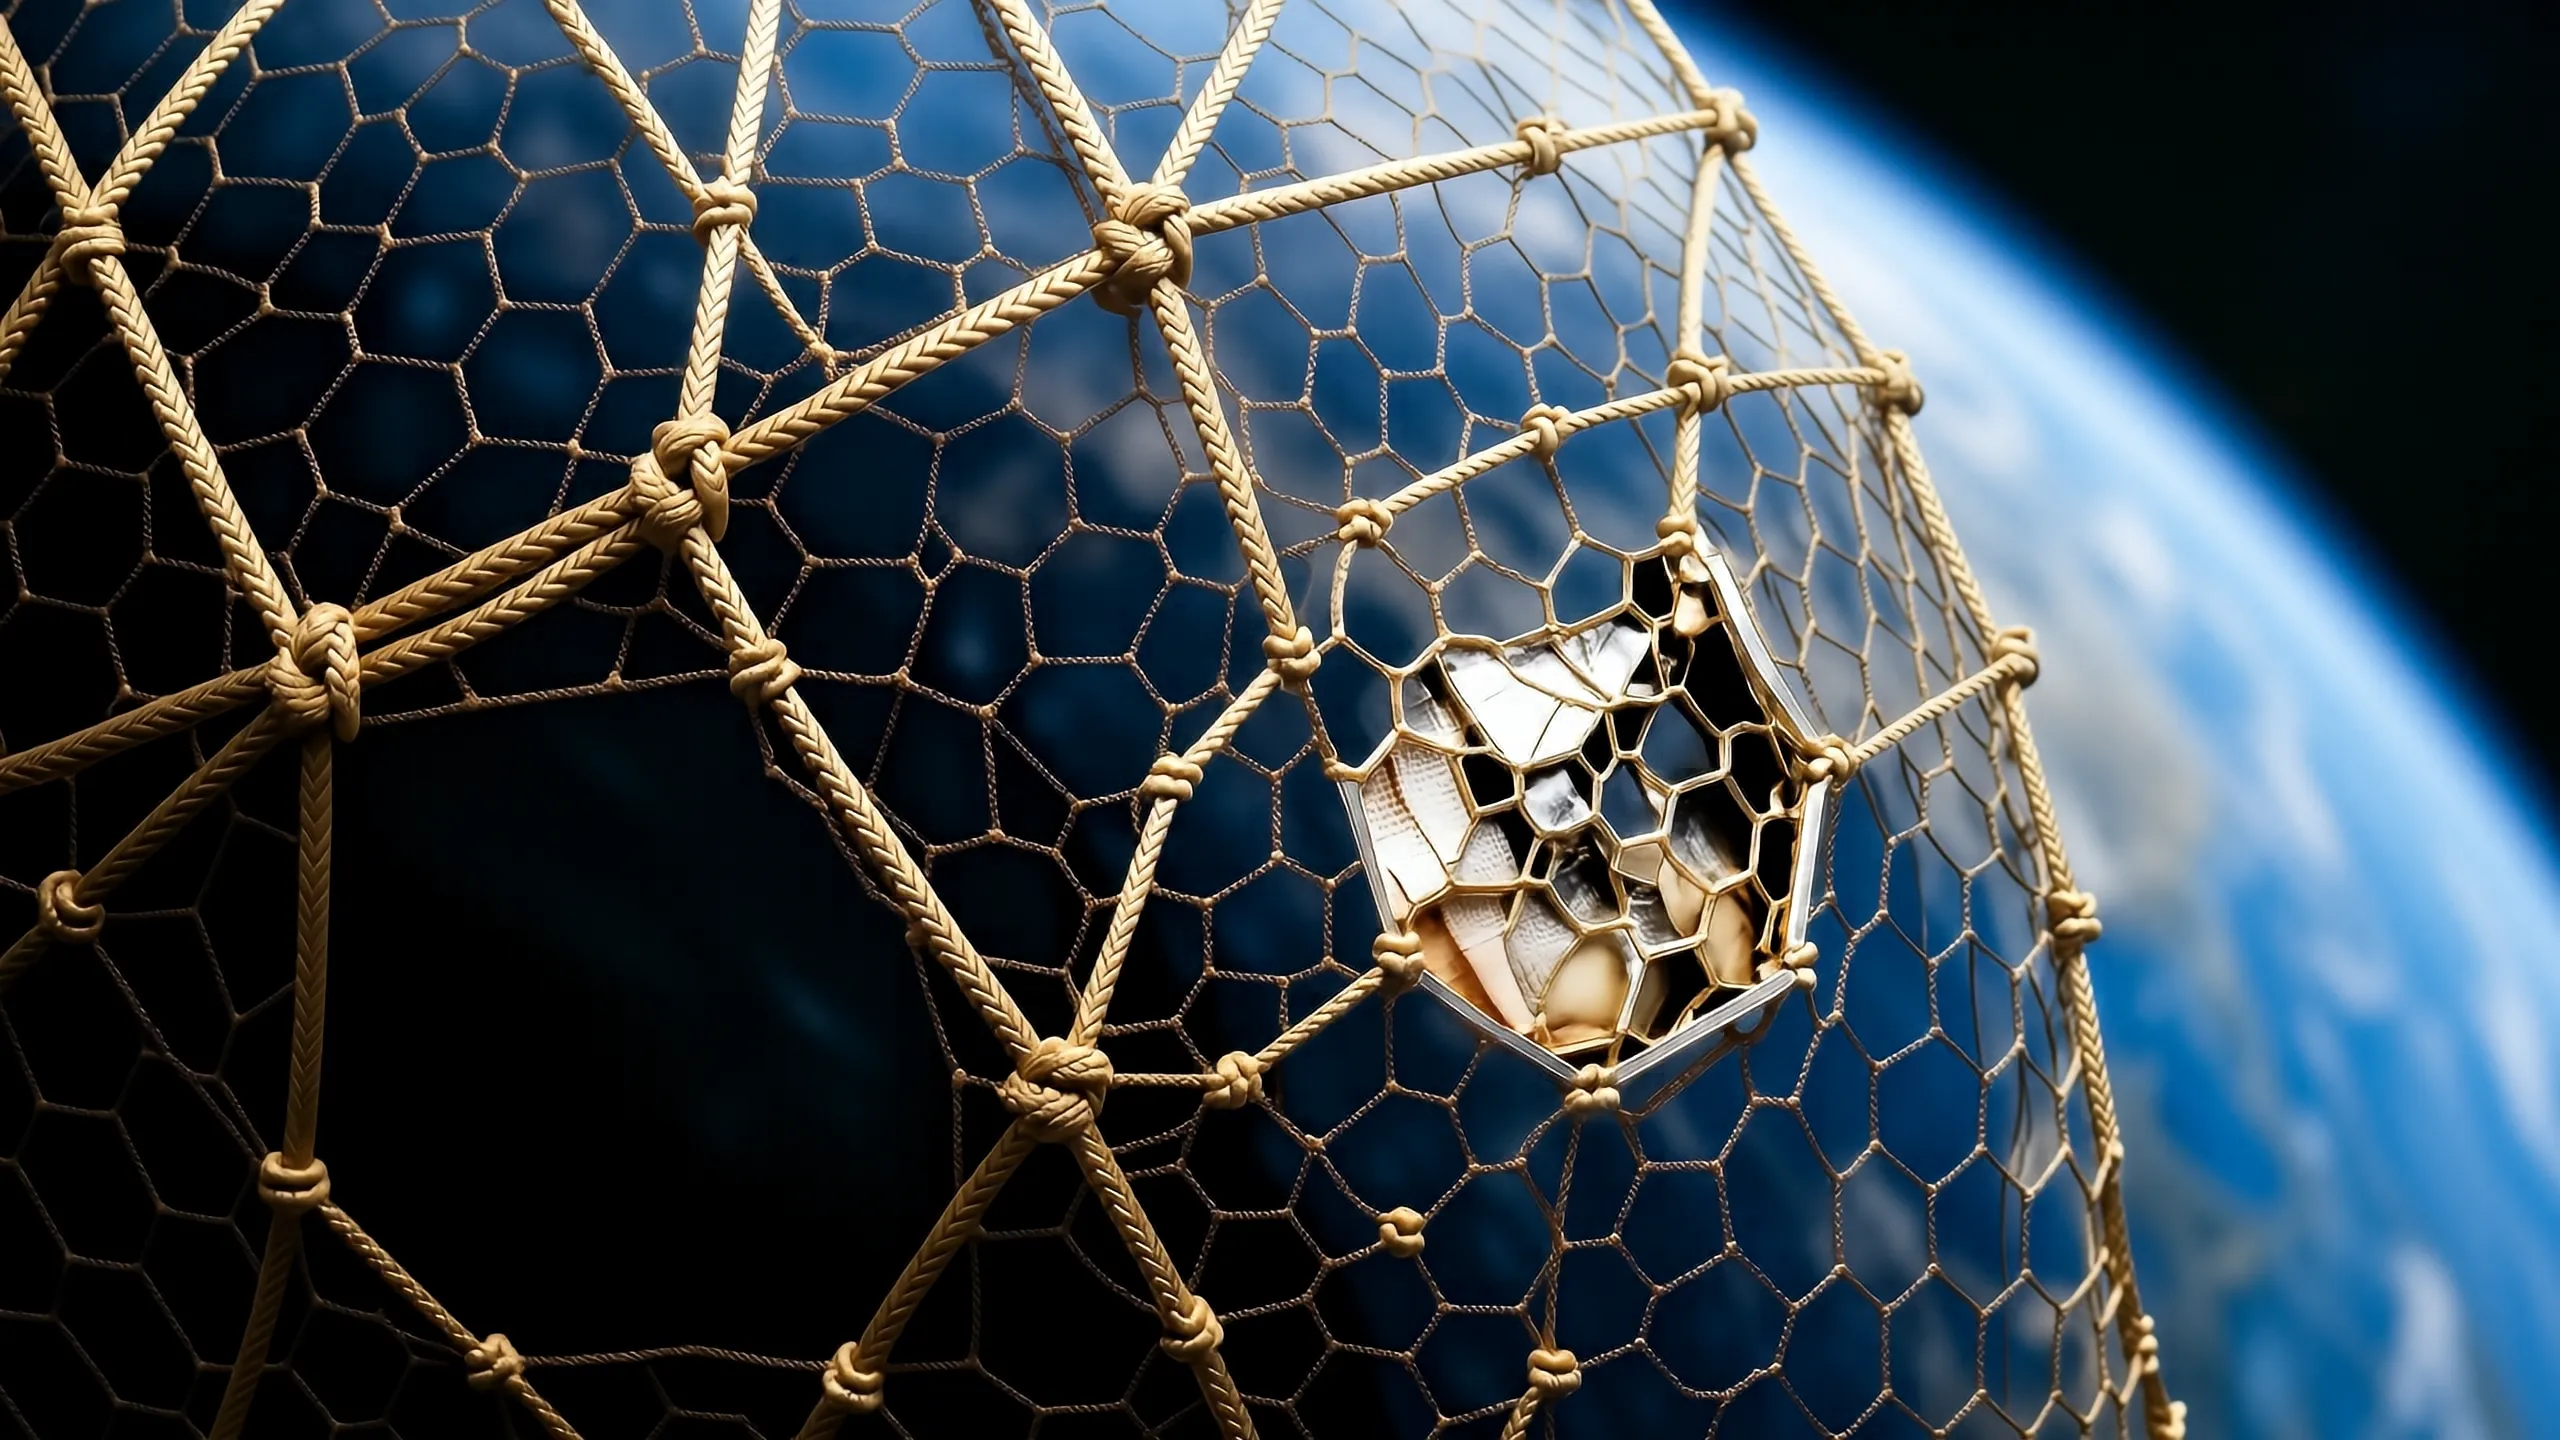 SDI’s fly-paper webbing concept: a compliant capture membrane that trades rigid precision for tolerance of an uncooperative, spinning target.
Bringing it down: disposal is half the mission
Capture is only half the job — a servicer clutching a two-ton rocket stage still has to dispose of it. Below about 600 kilometers, atmospheric drag does the work if you can increase a target’s area-to-mass ratio, which is why deployable drag sails are flying today as end-of-life devices. Electrodynamic tethers — kilometers of conductor generating drag through interaction with Earth’s magnetic field — promise propellant-free deorbit for heavier objects. For the largest debris, controlled destructive reentry over open ocean is the responsible endpoint, requiring precise burns so surviving fragments land where no one lives. In higher orbits, where reentry is impractical, disposal means boosting to graveyard orbits instead.
Choosing among these methods — and executing the long, perturbation-riddled descent — is a trajectory-optimization problem with many objectives: propellant, time, casualty risk, and traffic along the way down. This is the natural home of the trajectory AI that has been part of SDI’s vision from the start: reinforcement learning and modern optimal-control methods that plan fuel-efficient intercepts and descents, replan in seconds when the picture changes, and could one day coordinate multiple servicers working a debris field as a team.
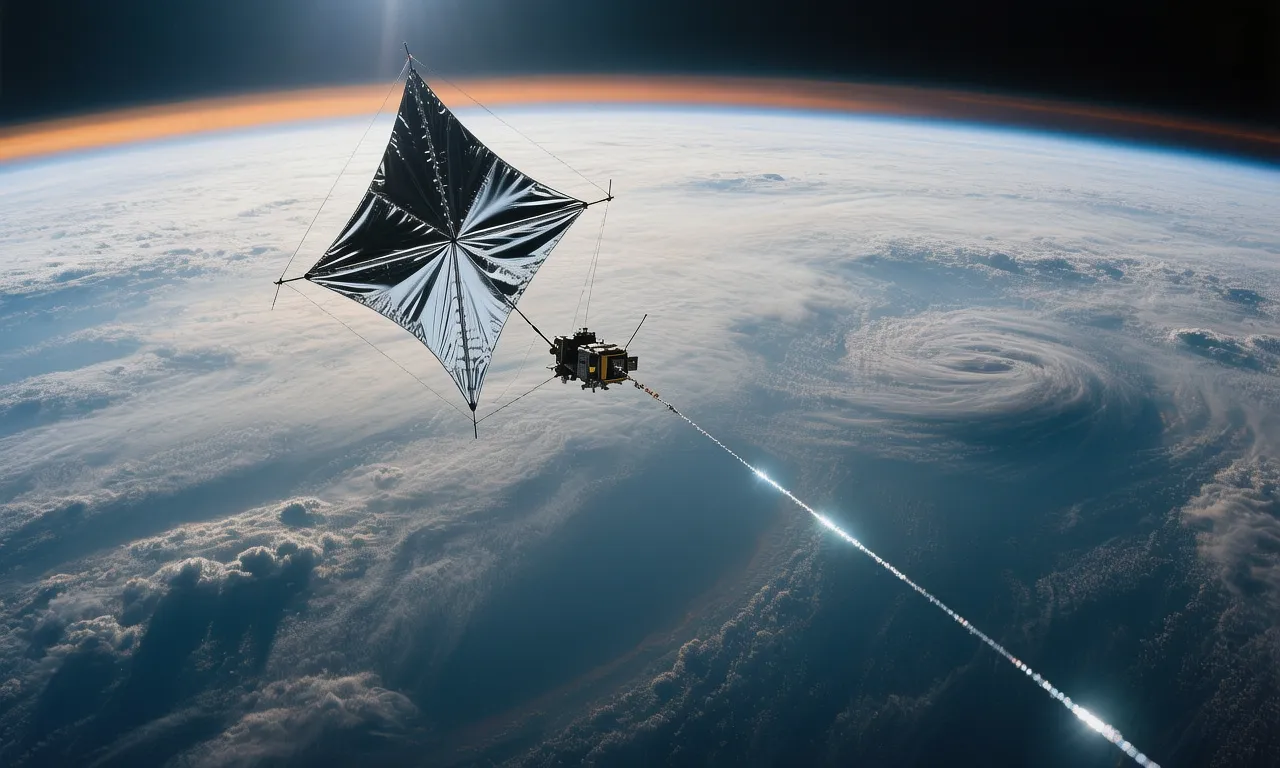 Disposal options span drag augmentation, electrodynamic tethers, and controlled reentry — matched to the target’s mass and orbit.
The Road Ahead
Space Dust Industries has not flown hardware, and we will not pretend otherwise. What we are building, deliberately and on the ground, is the layer every future removal mission will depend on: perception models that understand uncooperative objects from sparse sensor data, control policies trained in high-fidelity simulation, and edge AI that performs without a network connection — skills we exercise now through our GPU research cluster, our scan-to-print 3D pipeline, and our robotics and reinforcement-learning work as a NASA program subcontractor. The missions of the next decade — commercial removal services, national ADR programs, debris-aware traffic management — will be won by whoever solves the autonomy. That is the part of the problem we have chosen, and it is the part you can start solving from Colorado.